
Summary:
Just after expanding robot job openings, it has now dissolved the independent team—what exactly is OpenAI planning?
On November 13, at the Conference on Robot Learning (CoRL) held in Austin, USA, booth 208 reserved by OpenAI was empty.
The conference's booth map still marked OpenAI, but no company logo or product display was seen.
Subsequently, OpenAI confirmed to Fortune that it had dissolved its independent robotics research team.
The former robotics researchers joined the core research department led by Chief Research Officer Mark Chen, while robotics applications and hardware personnel were transferred to the Applied department headed by President Greg Brockman.
The company stated that robotics remains an important part of its long-term technology vision, and this adjustment is intended to accelerate R&D progress.
The news came somewhat suddenly.
In September of this year, OpenAI was still recruiting robotics R&D personnel on a large scale, with some positions offering base salaries as high as $500,000 per year. At the beginning of the year, the company's robotics data collection lab in San Francisco already had about 100 staff, and a second lab was being planned.
Sam Altman had also publicly stated that he expected to be able to demonstrate an impressive robot demo in 2027.
Investing in labs and hiring hardware engineers on one hand, while dissolving the independent research team on the other—how exactly does OpenAI plan to do robotics? And where will the R&D resources invested previously flow?
How much has OpenAI invested in the embodied field?
OpenAI has actually had one previous experience of dissolving a robotics team.
In 2019, the company demonstrated the Dactyl robotic hand solving a Rubik's cube. Researchers used large-scale simulation and reinforcement learning to enable the robot to master complex object manipulation capabilities.
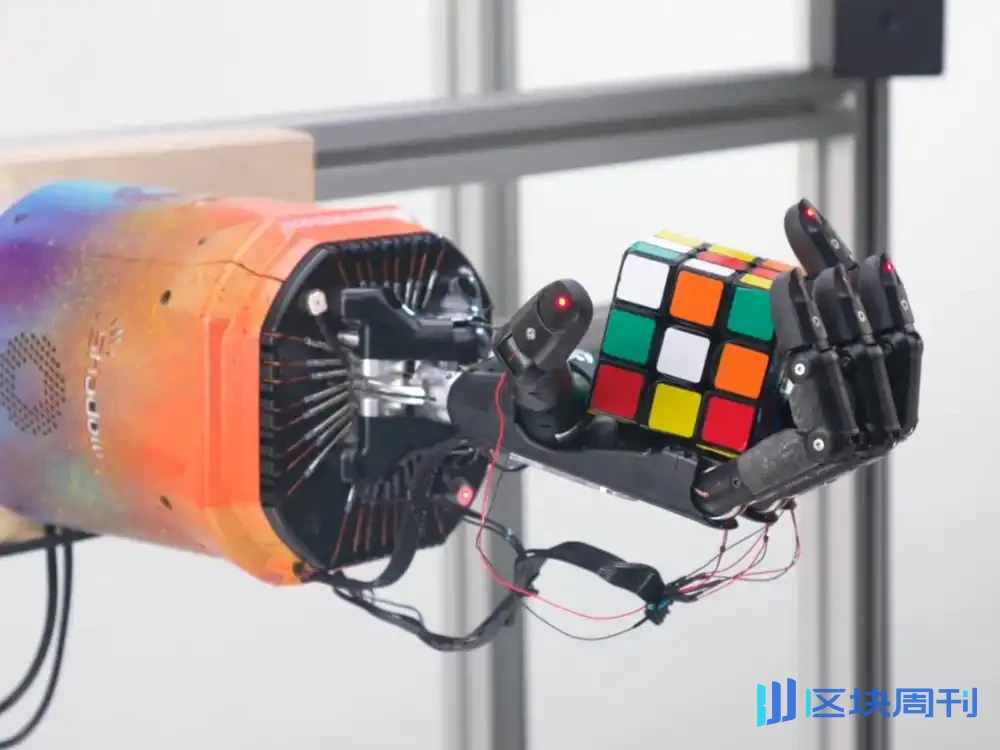
Image | In 2019, OpenAI demonstrated research results on controlling a robotic hand to solve a Rubik's cube through reinforcement learning
In 2020, OpenAI ended its first round of independent robotics research and shifted more focus to large-scale language models. This path later gave rise to ChatGPT.
In 2024, the company re-formed a robotics team and partnered with humanoid robotics company Figure to develop AI models. The partnership ended in February 2025, with Figure turning to self-developed robot models while OpenAI continued to expand internal R&D.
In January of this year, Business Insider investigated OpenAI's robotics data collection lab in San Francisco. The lab began construction in February 2025 and has since expanded more than fourfold, with about 100 data collection staff working in three shifts.
Staff use 3D-printed GELLO teleoperation controllers to operate Franka robotic arms to complete tasks such as folding clothes and putting bread into a toaster. The system records scenes and operation processes through cameras, accumulating data for robot model training.
Early tasks in the lab were quite simple, including putting a rubber duck into a cup, and only later did the difficulty of operations gradually increase.
The report also mentioned a detail: although there was a humanoid-robot-like device in the lab, the main data collection work was still carried out using robotic arms.
OpenAI also plans to build a second lab in Richmond, California.
For embodied intelligence companies, data collection is a considerable expense. Language models can use the large amount of text and images already available on the internet, while robots need to learn physical operations such as grasping, contact, and movement. Completing this data collection requires equipment, personnel, maintenance, and on-site management.
At that time, OpenAI was building its own data production system, and the scale of recruitment was also gradually expanding.
In September of this year, Business Insider counted that OpenAI's robotics-related job openings had increased from 11 in May to 27, covering directions such as machine learning, robot control, electronic engineering, actuators, firmware, and data collection, with some positions offering base salaries of up to $500,000.
As of November 14, a Phoenix Tech check of the official website found that OpenAI still publicly listed multiple robotics-related engineering positions.

Image | As of November 14, OpenAI's official website was still recruiting for embodied-related positions such as onboard robot computing, control software, motors and actuators
Previously, the company was also advancing supply chain preparations. In January of this year, OpenAI released a plan to solicit U.S. manufacturing suppliers, listing robotics together with data centers and consumer electronics in its hardware supply chain layout.
The solicitation scope involves key components such as motors, gearboxes, reducers, and power electronics. According to the original document, OpenAI plans to select suppliers in 2027, but has not yet disclosed the amount of the relevant procurement contracts.
In addition to engineering R&D, the funding arrangements for the robotics business have also entered management discussions.
In May of this year, The Wall Street Journal disclosed that Sam Altman had considered operating the robotics and consumer hardware businesses independently, allowing the relevant companies to raise funds separately from external investors.
The plan was ultimately not implemented. One reason was that even if the business were spun off, the relevant assets and profit and loss might still need to be included in the consolidated financial statements of the OpenAI group.
These records show that over the past year, OpenAI's investment in the robotics field has already involved data collection, model research, hardware engineering, and supply chain preparation.
After confirming the restructuring on November 13, OpenAI has not yet announced specific allocations for budget, personnel, and computing power, nor has it stated whether the data collection laboratory and prototype projects will be adjusted.

Wang Xingxing says the biggest mistake over the past decade-plus was not believing in AI enough
OpenAI explained the technical background of this adjustment to Fortune. At the beginning of this year, the company's researchers originally believed that using video generation models such as Sora to learn the laws of the physical world was an important path to advancing robot intelligence.
But general models such as GPT-6 Astra subsequently demonstrated the ability to directly control robots. OpenAI decided to merge the relevant researchers into the general foundation model team, allowing robotics research to leverage the latest advances in existing models.
Two speeches by Unitree Technology founder Wang Xingxing in the past month also align with this trend.
On October 12, during a roundtable discussion at the Shanghai Industrial Expo, Wang Xingxing said that after the release of GPT-6, Unitree had already integrated it into various robots to perform tasks, and the actual results exceeded previous expectations.
He admitted frankly: "The biggest mistake I've made over the past decade-plus is that I didn't believe in AI enough."

Image | On October 22, 2026, Wang Xingxing shared progress on general large models controlling robots at the World Physical AI Conference. Image source: The Paper
Wang Xingxing believes that AI models show marked progress almost every one or two months. If GPT-7 continues to make breakthroughs, the technical tipping point for embodied intelligence may arrive in the next one or two years.
On October 22, at the World Physical AI Conference, he again demonstrated an experiment in which a Unitree robot used GPT-6 to complete a painting. In front of the robot were a reference painting, white paper, paint, and clean water. It picked up a paintbrush to paint, switched colors during the process, and also washed the brush by itself. Unitree also demonstrated tasks such as the robot playing chess.
Wang Xingxing repeatedly emphasized that the team did not conduct specialized training for these tasks, nor did they write complex motion programs.
The robot itself still requires motion control and hardware systems, but the general model is already able to organize some operational steps based on the visuals and task requirements.
Previously, many robot tasks required developers to collect specialized motion demonstrations and then train corresponding operational policies. Now, general models can handle part of the visual understanding, spatial reasoning, and task planning work.
Anthropic's recently released Claude Fable 5.2 also provided experimental data.
On November 9, Anthropic demonstrated the process of Claude controlling a robotic arm to solve a Rubik's cube, twist off a bottle cap, and paint.
In the RoboDojo Sim simulation benchmark, tests run internally by Anthropic showed that Fable 5.2 achieved an average success rate of 64.9%, compared with 27.6% for the previous generation Fable 5.1, while GPT-6 Astra scored 29.8% under the same testing framework.

Image | The RoboDojo Sim simulation evaluation published by Anthropic, in which Claude Fable 5.2 achieved a score of 64.9%. Image source: Anthropic
NVIDIA's Astranomy research released in October directly used GPT-6 Astra to control simulated robots.
In the RoboLab-120 test, the direct control approach achieved a task success rate of 66.3%. After the researchers added mechanisms such as continuously recording operation history and checking execution results, the agent control approach reached 74.8%, higher than the previous best specialized robot model on this benchmark, which scored 51.0%.
Although these experiments used different testing environments, they all demonstrated the progress of general models in physical manipulation.
Guanya Shi, a robotics researcher at Carnegie Mellon University, said in an interview with Fortune that OpenAI may be viewing robotics as a downstream application of general intelligence.
For OpenAI, directly using general models means that some robot intelligence research can share the training results of core models. The return on investment of independently developing a set of robot foundation models therefore also needs to be reassessed.
However, the NVIDIA experiment also exposed another problem: the computational overhead of general models is quite high.
In the Astranomy research, the GPT-6 Astra direct control approach took an average of 18.56 seconds per inference.
Although the agent approach improved the success rate, each successful task episode consumed an average of about 30.9 million tokens, corresponding to an estimated API cost of $36.40.
These costs come from simulation testing and cannot be directly treated as the operating costs of real robots. But in actual factories, the longer a robot takes to execute a task, the higher the cost per unit of output may be.
What is more troublesome is latency. The simulation environment can pause during model inference, but conveyor belts, equipment, and workpieces in real factories will not stop and wait for more than ten seconds.
Robots still need systems that respond faster and can directly control the body's movements. This is also one of the reasons other tech companies continue to train specialized robot models.

Google, Nvidia, and Unitree are still training specialized models
On November 10, Google DeepMind announced an experiment in which the Apollo 2 humanoid robot worked in a Mercedes-Benz factory.
The robot grabs metal brackets from bins and places them into designated containers in production order. Test locations included Mercedes-Benz factories in Sindelfingen, Germany, and Kecskemét, Hungary. Google announced that the success rate of this parts sorting task reached 96%.

Image | Apollo 2 humanoid robot conducting parts sorting tests at a Mercedes-Benz automobile factory, image source: Google DeepMind
During operation, the two sets of models each perform their own duties.
Gemini Robotics ER is responsible for understanding the production process and judging task progress; Gemini Robotics 2.5, trained on robot motions, is responsible for the actual operation of the arms and dexterous hands. Google also used Gemini 4 Argon to help build simulation environments and analyze failure cases.
Apptronik CEO Jeff Cardenas said that Apollo 2 showed significant improvement after several weeks of post-training, and after being transferred to the Mercedes-Benz production line, the performance decline was relatively small.
This is a proof of concept in a limited scenario, and the failure rate and production cost of long-term operation have not yet been disclosed. But Google has already demonstrated how a general reasoning model and a specialized action model can work together to complete factory tasks.
Nvidia's GR00T 2, released in November, focuses on the training cost after robots enter new scenarios.

Image | GR00T 2 reads the most recent video, instructions, and robot state, performs denoising on future video and action segments, executes that action segment, and then repeats this process
In 50 tasks that had not previously been trained for the target robot, GR00T 2 achieved an average zero-shot success rate of 40%. The researchers added 5 demonstration operations and less than 3 minutes of robot data for each task, then fine-tuned for about 30 minutes using a single RTX 5090, raising the success rate to 95%.
When robots arrive at a new factory, they often need to re-adapt to item placement, grasping order, and specific equipment. Being able to complete task adaptation with a small number of demonstrations may reduce investment in data collection, on-site debugging, and engineer presence.
But robots still have to solve physical errors in precision operations.
On November 5, Wang Xingxing mentioned at the Hongqiao Forum of the China International Import Expo that current top multimodal models already have strong understanding and planning capabilities, but tasks such as parts insertion are still prone to getting stuck in the last few millimeters.
Picking up a box can tolerate a certain positional deviation, while inserting a connector must handle angle, friction, and contact force. A slight deviation in movement may damage the workpiece.
Nvidia conducted real-machine reinforcement learning for these tasks. In the experiments it published, the trained robot achieved a 94% success rate in cable insertion tasks and 96% in charger insertion.
Unitree and AgiBot are also continuing to train their own robot models. Unitree's publicly released UnifoLM-WLA-1.0 uses about 2,500 hours of real-machine data, while AgiBot continues to invest in robot operation data and post-training through GO-3 Preview and Genie Evolver.
In a typical precision assembly task, a general model can understand the operational requirements and arrange the execution order, while a specialized action model needs to learn how different robotic arms approach parts, adjust positions, and handle contact feedback. To run continuously, the underlying control system is also needed to handle anomalies in a timely manner.
This kind of division of labor does not require every company to train from scratch a set of foundation models responsible for understanding and planning. Robot companies can use external models and then train action capabilities for their own bodies, customer tasks, and on-site data.
For OpenAI, merging robotics research into the GPT team is precisely choosing to solve more robot intelligence problems within the general model system. The data collection and hardware R&D capabilities already built can then be used to test the effects of these models on real robots.
(The header image of this article was generated by AI)
This article is from the WeChat public account: Phoenix Tech , author: Phoenix Tech, editor: Dong Yuqing, original title: "Just Offering a 3.3 Million Yuan Annual Salary to Poach Talent, OpenAI Suddenly Dissolves Its Robotics Team—Is the Industry About to Change!"





